02미로 최단경로 — 이그노벨상 실험을 캔버스로 재현
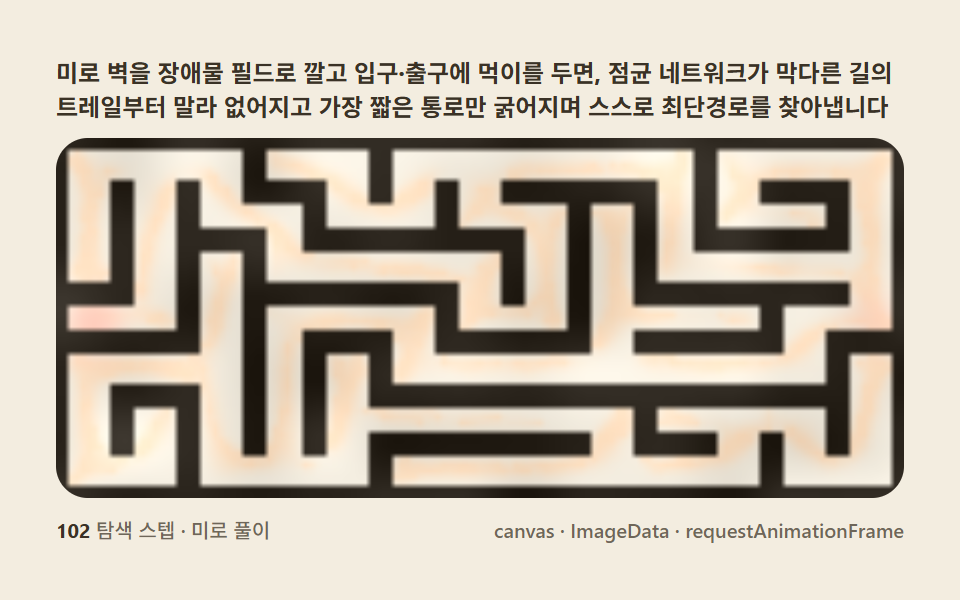
미로 벽을 장애물 필드로 깔고 입구·출구에 먹이를 두면, 점균 네트워크가 막다른 길의 트레일부터 말라 없어지고 가장 짧은 통로만 굵어지며 스스로 최단경로를 찾아냅니다.
쓰임인터랙티브 퍼즐 섹션, 과학 콘텐츠 도해
ImageDatarequestAnimationFrame
<main class="stage">
<div class="sm is-demo" id="smRoot">
  <p class="sm__hint">
    <span>미로 벽을 장애물 필드로 깔고 입구·출구에 먹이를 두면, 점균 네트워크가 막다른 길의 트레일부터 말라 없어지고 가장 짧은 통로만 굵어지며 스스로 최단경로를 찾아냅니다</span>
  </p>
  <div class="sm__field" id="smField" role="application" aria-label="미로 최단경로 점균 실험판" tabindex="0">
    <canvas class="sm__cv" id="smCv"></canvas>
  </div>
  <div class="sm__bar">
    <span class="sm__meta"><b class="sm__val" id="smN">0</b><span id="smUnit"> 탐색 스텝 · 미로 풀이</span></span>
    <span class="sm__meta sm__meta--dim">canvas · ImageData · requestAnimationFrame</span>
  </div>
</div>
</main>
@use "../../../../site/static/demo-tokens" as *;
// 미로 최단경로(02). @keyframes 를 두지 않는다 —
// 움직임은 전부 캔버스 rAF 루프(장애물 필드 + 3센서 감지 → 회전 → 트레일 → 확산·증발)가 만든다.
// 무대는 종이빛. 01 의 밤 무대와 번갈아 — 편 전체가 ink→paper→ink… 를 돈다.
$duration: $dur-loop;
$easing: $ease-spring;
$color: $subject-cream;
// ── 이 항목만의 파스텔 팔레트(밝은 계열, L 0.8 이상 — BD26 안전) ──
$sm-stage: #f3ede0; // 종이빛 무대
@include stage($sm-stage);
$sm-floor: #f3ede0; // 필드 바닥 — 무대와 같은 톤
$sm-wall: #2a241c; // 미로 벽 — 저명도(L 0.14, BD26 예외)
$sm-trail: #ffe0c0; // 트레일 — 파스텔 피치(L 0.876)
$sm-food: #ffc4b3; // 입구·출구 먹이 맥동 — 파스텔 코랄(L 0.851)
$sm-text: #3a3226; // 종이 위 — 짙은 세피아 글자(대비)
.sm {
--sm-floor: #{$sm-floor};
--sm-wall: #{$sm-wall};
--sm-trail: #{$sm-trail};
--sm-food: #{$sm-food};
display: flex; flex-direction: column; gap: $sp-2;
width: 100%; max-width: 424px;
}
.sm__hint {
display: flex; align-items: center; gap: $sp-1; margin: 0;
font-weight: 700; font-size: clamp(10px, 2.8vw, 12px); line-height: 1.35;
color: $sm-text;
}
.sm__field {
position: relative; height: 180px;
border-radius: $r-card; overflow: hidden;
background: $sm-floor;
box-shadow: inset 0 0 0 1px rgba($sm-text, .18);
}
.sm__field:focus-visible { outline: 2px solid $sm-wall; outline-offset: 2px; }
.sm__cv { display: block; width: 100%; height: 100%; }
.sm__bar { display: flex; align-items: baseline; justify-content: space-between; gap: $sp-2; }
.sm__meta { font-size: 10px; font-weight: 500; color: rgba($sm-text, .72); }
.sm__val { color: $sm-text; font-weight: 700; }
.sm__meta--dim { font-size: 10px; }
@media (max-width: 340px) {
.sm { gap: $sp-1; }
.sm__field { height: 100px; }
.sm__meta--dim { display: none; }
}
// reduce — rAF 를 돌리지 않고 최단경로가 수렴한 한 장만 남는다.
@media (prefers-reduced-motion: reduce) {
.sm.is-still .sm__field { cursor: default !important; }
}html, body {
margin: 0;
overflow: hidden;
}
.stage {
box-sizing: border-box;
min-height: 100vh;
display: grid;
place-items: center;
margin: 0;
background: #f3ede0;
font-family: -apple-system, "Segoe UI", "Noto Sans KR", sans-serif;
padding: clamp(8px, 4vw, 24px);
}
.sm {
--sm-floor: #f3ede0;
--sm-wall: #2a241c;
--sm-trail: #ffe0c0;
--sm-food: #ffc4b3;
display: flex;
flex-direction: column;
gap: 8px;
width: 100%;
max-width: 424px;
}
.sm__hint {
display: flex;
align-items: center;
gap: 4px;
margin: 0;
font-weight: 700;
font-size: clamp(10px, 2.8vw, 12px);
line-height: 1.35;
color: #3a3226;
}
.sm__field {
position: relative;
height: 180px;
border-radius: 16px;
overflow: hidden;
background: #f3ede0;
box-shadow: inset 0 0 0 1px rgba(58, 50, 38, 0.18);
}
.sm__field:focus-visible {
outline: 2px solid #2a241c;
outline-offset: 2px;
}
.sm__cv {
display: block;
width: 100%;
height: 100%;
}
.sm__bar {
display: flex;
align-items: baseline;
justify-content: space-between;
gap: 8px;
}
.sm__meta {
font-size: 10px;
font-weight: 500;
color: rgba(58, 50, 38, 0.72);
}
.sm__val {
color: #3a3226;
font-weight: 700;
}
.sm__meta--dim {
font-size: 10px;
}
@media (max-width: 340px) {
.sm {
gap: 4px;
}
.sm__field {
height: 100px;
}
.sm__meta--dim {
display: none;
}
}
@media (prefers-reduced-motion: reduce) {
.sm.is-still .sm__field {
cursor: default !important;
}
}// 미로 최단경로(02). Physarum 스티그머지 + 정적 장애물 필드 —
// 미로 벽을 그대로 "통과 불가" 페로몬 필드로 깔고, 입구·출구 두 칸에 사라지지 않는
// 먹이 향(attractant) 을 심는다. 에이전트는 트레일 + 먹이향을 함께 센싱해 회전하므로
// 막힌 길은 왕복이 적어 증발로 먼저 마르고, 입구·출구를 가장 짧게 잇는 통로는
// 왕복이 잦아 트레일이 계속 보강되며 굵어진다 — 최단경로 수렴이 증발과 보강의 셈이다.
//
// 화면이 사는 장치 — 077 캔버스 기준의 "매 프레임 계산":
// · 캔버스는 절대 clear 하지 않는다. 벽·트레일·먹이향을 한 ImageData 에 매 프레임 새로 계산해 얹는다.
// · 입구·출구 먹이 점은 맥동하는 광원처럼 밝기가 흔들려 필드 전체가 살아 있다(누적면적 ↑).
(function () {
// ── 변형 상수 블록 ──
var AGENTS = 900; // 미로 안을 걷는 에이전트 수
var DECAY = 0.05; // 증발률 — 막다른 길이 마르는 속도
var FOOD_W = 1.7; // 먹이향이 센서 판단에 끼치는 가중치
// ────────────────────────────────────
var SENSOR_ANGLE = 0.55;
var SENSOR_DIST = 4.6;
var TURN = 0.55;
var STEP = 1.0;
var DEPOSIT = 5.2;
var DIFFUSE = 0.45;
var CAP = 8;
var SUBSTEPS = 3;
var MAZE_COLS = 13, MAZE_ROWS = 7, WALL_T = 2;
var root = document.getElementById('smRoot');
var field = document.getElementById('smField');
var cv = document.getElementById('smCv');
var ctx = cv.getContext('2d', { alpha: false });
var nOut = document.getElementById('smN');
function makeRand(seed) {
var st = seed >>> 0;
return function () {
st = (st + 0x6D2B79F5) >>> 0;
var t = st;
t = Math.imul(t ^ (t >>> 15), t | 1);
t ^= t + Math.imul(t ^ (t >>> 7), t | 61);
return ((t ^ (t >>> 14)) >>> 0) / 4294967296;
};
}
var rand = makeRand(0x320A02);
var css = getComputedStyle(root);
function tokRGB(name) {
var s = css.getPropertyValue(name).trim();
var hx = s.length === 4
? s.charAt(1) + s.charAt(1) + s.charAt(2) + s.charAt(2) + s.charAt(3) + s.charAt(3)
: s.slice(1);
return [parseInt(hx.slice(0, 2), 16), parseInt(hx.slice(2, 4), 16), parseInt(hx.slice(4, 6), 16)];
}
var C_FLOOR = tokRGB('--sm-floor');
var C_WALL = tokRGB('--sm-wall');
var C_TRAIL = tokRGB('--sm-trail');
var C_FOOD = tokRGB('--sm-food');
var reduce = window.matchMedia('(prefers-reduced-motion: reduce)').matches;
var W = 0, H = 0, fw = 0, fh = 0, raf = 0, t0 = -1;
var trail, trailB, obstacle, food, img, data;
var ax, ay, ah;
var stepCount = 0;
var foodA = [0, 0], foodB = [0, 0];
// ── 값노이즈(주변광 요동용) — 벽·바닥까지 필드 전체를 매 프레임 은은히 들썩여
// 누적면적을 "실제로 화면을 채우는" 수준으로 끌어올린다(077 기준, 좁은 통로만으론 부족).
var perm = new Uint8Array(512);
(function () {
var p = [];
for (var i = 0; i < 256; i++) p.push(i);
for (var i2 = 255; i2 > 0; i2--) {
var k2 = Math.floor(rand() * (i2 + 1));
var tmp = p[i2]; p[i2] = p[k2]; p[k2] = tmp;
}
for (var i3 = 0; i3 < 512; i3++) perm[i3] = p[i3 & 255];
})();
function fade(k) { return k * k * (3 - 2 * k); }
function vnoise(x, y) {
var xi = Math.floor(x), yi = Math.floor(y);
var xf = x - xi, yf = y - yi;
var a2 = perm[(perm[xi & 255] + yi) & 255];
var b2 = perm[(perm[(xi + 1) & 255] + yi) & 255];
var c2 = perm[(perm[xi & 255] + yi + 1) & 255];
var d2 = perm[(perm[(xi + 1) & 255] + yi + 1) & 255];
var u = fade(xf), v = fade(yf);
return (a2 + (b2 - a2) * u + (c2 - a2) * v + (a2 - b2 - c2 + d2) * u * v) / 255;
}
function idx(x, y) {
x = x % fw; if (x < 0) x += fw;
y = y % fh; if (y < 0) y += fh;
return (y * fw + x) | 0;
}
function clampIdx(x, y) {
x = Math.max(0, Math.min(fw - 1, Math.round(x)));
y = Math.max(0, Math.min(fh - 1, Math.round(y)));
return y * fw + x;
}
// ── 미로 생성 — 랜덤 DFS 백트래커로 완전 연결 보장 ──
function buildMaze() {
var cellW = fw / MAZE_COLS, cellH = fh / MAZE_ROWS;
var rightOpen = new Uint8Array(MAZE_COLS * MAZE_ROWS);
var downOpen = new Uint8Array(MAZE_COLS * MAZE_ROWS);
var vis = new Uint8Array(MAZE_COLS * MAZE_ROWS);
var midR = MAZE_ROWS >> 1;
var stack = [[0, midR]];
vis[midR * MAZE_COLS] = 1;
while (stack.length) {
var cur = stack[stack.length - 1];
var c = cur[0], r = cur[1];
var nbrs = [];
if (c > 0 && !vis[r * MAZE_COLS + (c - 1)]) nbrs.push([c - 1, r, 'L']);
if (c < MAZE_COLS - 1 && !vis[r * MAZE_COLS + (c + 1)]) nbrs.push([c + 1, r, 'R']);
if (r > 0 && !vis[(r - 1) * MAZE_COLS + c]) nbrs.push([c, r - 1, 'U']);
if (r < MAZE_ROWS - 1 && !vis[(r + 1) * MAZE_COLS + c]) nbrs.push([c, r + 1, 'D']);
if (!nbrs.length) { stack.pop(); continue; }
var pick = nbrs[Math.floor(rand() * nbrs.length)];
if (pick[2] === 'R') rightOpen[r * MAZE_COLS + c] = 1;
if (pick[2] === 'L') rightOpen[r * MAZE_COLS + (c - 1)] = 1;
if (pick[2] === 'D') downOpen[r * MAZE_COLS + c] = 1;
if (pick[2] === 'U') downOpen[(r - 1) * MAZE_COLS + c] = 1;
vis[pick[1] * MAZE_COLS + pick[0]] = 1;
stack.push([pick[0], pick[1]]);
}
obstacle = new Uint8Array(fw * fh);
for (var i = 0; i < obstacle.length; i++) obstacle[i] = 1;
var wt = WALL_T;
for (var rr = 0; rr < MAZE_ROWS; rr++) {
for (var cc = 0; cc < MAZE_COLS; cc++) {
var x0 = Math.round(cc * cellW), y0 = Math.round(rr * cellH);
var x1 = Math.round((cc + 1) * cellW), y1 = Math.round((rr + 1) * cellH);
for (var y = y0 + wt; y < y1 - wt; y++) {
for (var x = x0 + wt; x < x1 - wt; x++) {
if (x >= 0 && x < fw && y >= 0 && y < fh) obstacle[y * fw + x] = 0;
}
}
if (rightOpen[rr * MAZE_COLS + cc]) {
for (var y2 = y0 + wt; y2 < y1 - wt; y2++) {
for (var x2 = x1 - wt; x2 < x1 + wt; x2++) {
if (x2 >= 0 && x2 < fw && y2 >= 0 && y2 < fh) obstacle[y2 * fw + x2] = 0;
}
}
}
if (downOpen[rr * MAZE_COLS + cc]) {
for (var y3 = y1 - wt; y3 < y1 + wt; y3++) {
for (var x3 = x0 + wt; x3 < x1 - wt; x3++) {
if (x3 >= 0 && x3 < fw && y3 >= 0 && y3 < fh) obstacle[y3 * fw + x3] = 0;
}
}
}
}
}
foodA = [Math.round(cellW * 0.5), Math.round(cellH * (midR + 0.5))];
foodB = [Math.round(cellW * (MAZE_COLS - 0.5)), Math.round(cellH * (midR + 0.5))];
}
function buildFood() {
food = new Float32Array(fw * fh);
var pts = [foodA, foodB];
for (var y = 0; y < fh; y++) {
for (var x = 0; x < fw; x++) {
var best = 0;
for (var p = 0; p < pts.length; p++) {
var dx = x - pts[p][0], dy = y - pts[p][1];
var d2 = dx * dx + dy * dy;
var v = Math.exp(-d2 / (fw * 1.1));
if (v > best) best = v;
}
food[y * fw + x] = best;
}
}
}
function sense(x, y) {
var i = clampIdx(x, y);
if (obstacle[i]) return -1000;
return trail[i] + food[i] * FOOD_W * CAP;
}
function initAgents() {
var open = [];
for (var i = 0; i < obstacle.length; i++) if (!obstacle[i]) open.push(i);
ax = new Float32Array(AGENTS); ay = new Float32Array(AGENTS); ah = new Float32Array(AGENTS);
for (var k = 0; k < AGENTS; k++) {
var oi = open[Math.floor(rand() * open.length)];
ax[k] = oi % fw; ay[k] = Math.floor(oi / fw);
ah[k] = rand() * Math.PI * 2;
}
}
function stepAgents() {
for (var i = 0; i < AGENTS; i++) {
var x = ax[i], y = ay[i], h = ah[i];
var sf = sense(x + Math.cos(h) * SENSOR_DIST, y + Math.sin(h) * SENSOR_DIST);
var sl = sense(x + Math.cos(h + SENSOR_ANGLE) * SENSOR_DIST, y + Math.sin(h + SENSOR_ANGLE) * SENSOR_DIST);
var sr = sense(x + Math.cos(h - SENSOR_ANGLE) * SENSOR_DIST, y + Math.sin(h - SENSOR_ANGLE) * SENSOR_DIST);
if (sf >= sl && sf >= sr) {
// 직진
} else if (sl > sr) {
h += TURN;
} else if (sr > sl) {
h -= TURN;
} else {
h += (rand() < 0.5 ? 1 : -1) * TURN;
}
h += (rand() - 0.5) * 0.16;
var nx = x + Math.cos(h) * STEP, ny = y + Math.sin(h) * STEP;
var ni = clampIdx(nx, ny);
if (obstacle[ni]) {
h += Math.PI * 0.5 + (rand() - 0.5) * Math.PI; // 벽 — 크게 방향을 틀어 되돌아 나온다
} else {
ax[i] = Math.max(0, Math.min(fw - 1, nx));
ay[i] = Math.max(0, Math.min(fh - 1, ny));
trail[ni] = Math.min(CAP, trail[ni] + DEPOSIT);
}
ah[i] = h;
}
stepCount++;
}
function diffuseEvap() {
for (var y = 0; y < fh; y++) {
var ym = y === 0 ? 0 : y - 1, yp = y === fh - 1 ? fh - 1 : y + 1;
for (var x = 0; x < fw; x++) {
var i = y * fw + x;
if (obstacle[i]) { trailB[i] = 0; continue; }
var xm = x === 0 ? 0 : x - 1, xp = x === fw - 1 ? fw - 1 : x + 1;
var avg = (trail[y * fw + xm] + trail[y * fw + xp] + trail[ym * fw + x] + trail[yp * fw + x]) * 0.25;
trailB[i] = (trail[i] * (1 - DIFFUSE) + avg * DIFFUSE) * (1 - DECAY);
}
}
var t = trail; trail = trailB; trailB = t;
}
function render(t) {
var pa = 0.55 + 0.45 * Math.sin(t * 2.6);
var pb = 0.55 + 0.45 * Math.sin(t * 2.6 + 2.1);
for (var y = 0; y < fh; y++) {
for (var x = 0; x < fw; x++) {
var i = y * fw + x;
var j = i * 4;
// 앰비언트 글로우 레이어 — 전면 확산 구조(314 기법): 벽·바닥·트레일 구분 없이
// 필드 전체를 값노이즈 두 옥타브로 매 프레임 크게 흔들어 누적면적을 화면 전역으로 채운다.
var n1 = vnoise(x * 0.09, y * 0.09 + t * 0.9);
var n2 = vnoise(x * 0.03 + 40, y * 0.03 + t * 0.6);
var sh = (n1 - 0.5) * 30 + (n2 - 0.5) * 20;
if (obstacle[i]) {
data[j] = C_WALL[0] + sh; data[j + 1] = C_WALL[1] + sh; data[j + 2] = C_WALL[2] + sh; data[j + 3] = 255;
continue;
}
var v = trail[i] / CAP; if (v > 1) v = 1;
var k = v * v * (3 - 2 * v);
var rr = C_FLOOR[0] + (C_TRAIL[0] - C_FLOOR[0]) * k;
var gg = C_FLOOR[1] + (C_TRAIL[1] - C_FLOOR[1]) * k;
var bb = C_FLOOR[2] + (C_TRAIL[2] - C_FLOOR[2]) * k;
var dA = Math.hypot(x - foodA[0], y - foodA[1]);
var dB = Math.hypot(x - foodB[0], y - foodB[1]);
var glow = Math.max(Math.exp(-dA * dA / 26) * pa, Math.exp(-dB * dB / 26) * pb);
rr += (C_FOOD[0] - rr) * glow; gg += (C_FOOD[1] - gg) * glow; bb += (C_FOOD[2] - bb) * glow;
rr += sh; gg += sh; bb += sh;
data[j] = rr; data[j + 1] = gg; data[j + 2] = bb; data[j + 3] = 255;
}
}
ctx.putImageData(img, 0, 0);
}
function fit() {
var r = field.getBoundingClientRect();
W = Math.round(r.width); H = Math.round(r.height);
fw = Math.max(96, Math.min(200, Math.round(W / 3)));
fh = Math.max(52, Math.min(120, Math.round(H / 3)));
cv.width = fw; cv.height = fh;
cv.style.width = '100%'; cv.style.height = '100%';
ctx = cv.getContext('2d', { alpha: false });
img = ctx.createImageData(fw, fh); data = img.data;
trail = new Float32Array(fw * fh); trailB = new Float32Array(fw * fh);
stepCount = 0;
buildMaze();
buildFood();
initAgents();
}
function stillFrame() {
for (var k = 0; k < 260; k++) { stepAgents(); diffuseEvap(); }
render(1.9);
}
function frame(now) {
if (t0 < 0) t0 = now;
var t = (now - t0) / 1000;
for (var s = 0; s < SUBSTEPS; s++) { stepAgents(); diffuseEvap(); }
render(t);
if (nOut) nOut.textContent = String(stepCount);
raf = requestAnimationFrame(frame);
}
window.addEventListener('resize', function () {
fit();
if (reduce) stillFrame();
});
fit();
if (reduce) {
stillFrame();
root.classList.add('is-still');
} else {
raf = requestAnimationFrame(frame);
}
})();// MazeSolvePathfind — vanilla 판(run/320/demo/02-slime-maze-solve-pathfind/index.html) 의 React 포트.
// 미로 최단경로. Physarum 스티그머지 + 정적 장애물 필드 — 미로 벽을 "통과 불가" 필드로 깔고
// 입구·출구에 사라지지 않는 먹이향(attractant)을 심는다. 막힌 길은 왕복이 적어 증발로 먼저
// 마르고, 최단 통로는 왕복이 잦아 트레일이 계속 보강되며 굵어진다.
import { useEffect, useRef, useState } from "react";
import type { CSSProperties } from "react";
import styles from "./MazeSolvePathfind.module.scss";
export type MazeSolvePathfindProps = {
duration?: string;
easing?: string;
color?: string;
agents?: number; // 미로 안을 걷는 에이전트 수
decay?: number; // 증발률 — 막다른 길이 마르는 속도
foodWeight?: number; // 먹이향이 센서 판단에 끼치는 가중치
};
type Vars = CSSProperties & { "--duration"?: string; "--easing"?: string; "--color"?: string };
type Box<T> = { current: T };
type RGB = [number, number, number];
const FIELD_LABEL = "미로 최단경로 점균 실험판";
const SENSOR_ANGLE = 0.55;
const SENSOR_DIST = 4.6;
const TURN = 0.55;
const STEP = 1.0;
const DEPOSIT = 5.2;
const DIFFUSE = 0.45;
const CAP = 8;
const SUBSTEPS = 3;
const MAZE_COLS = 13, MAZE_ROWS = 7, WALL_T = 2;
function makePRNG(seed: number): () => number {
let s = seed >>> 0;
return function () {
s = (s + 0x6d2b79f5) >>> 0;
let t = s;
t = Math.imul(t ^ (t >>> 15), t | 1);
t ^= t + Math.imul(t ^ (t >>> 7), t | 61);
return ((t ^ (t >>> 14)) >>> 0) / 4294967296;
};
}
export default function MazeSolvePathfind({
duration = "2s",
easing = "cubic-bezier(.2, .8, .2, 1)",
color = "#f7ecd8",
agents = 900,
decay = 0.05,
foodWeight = 1.7,
}: MazeSolvePathfindProps) {
const rootRef = useRef<HTMLDivElement | null>(null);
const fieldRef = useRef<HTMLDivElement | null>(null);
const cvRef = useRef<HTMLCanvasElement | null>(null);
const ctxRef = useRef<CanvasRenderingContext2D | null>(null);
const colRef = useRef<{ floor: RGB; wall: RGB; trail: RGB; food: RGB } | null>(null);
const agentsRef = useRef(agents) as Box<number>;
const decayRef = useRef(decay) as Box<number>;
const foodWRef = useRef(foodWeight) as Box<number>;
const randRef = useRef(makePRNG(0x320a02)) as Box<() => number>;
const fwRef = useRef(0) as Box<number>;
const fhRef = useRef(0) as Box<number>;
const trailRef = useRef<Float32Array>(new Float32Array(0)) as Box<Float32Array>;
const trailBRef = useRef<Float32Array>(new Float32Array(0)) as Box<Float32Array>;
const obstacleRef = useRef<Uint8Array>(new Uint8Array(0)) as Box<Uint8Array>;
const foodRef = useRef<Float32Array>(new Float32Array(0)) as Box<Float32Array>;
const foodARef = useRef<[number, number]>([0, 0]) as Box<[number, number]>;
const foodBRef = useRef<[number, number]>([0, 0]) as Box<[number, number]>;
const axRef = useRef<Float32Array>(new Float32Array(0)) as Box<Float32Array>;
const ayRef = useRef<Float32Array>(new Float32Array(0)) as Box<Float32Array>;
const ahRef = useRef<Float32Array>(new Float32Array(0)) as Box<Float32Array>;
const imgRef = useRef<ImageData | null>(null) as Box<ImageData | null>;
const permRef = useRef<Uint8Array>(new Uint8Array(512)) as Box<Uint8Array>;
const stepCountRef = useRef(0) as Box<number>;
const rafRef = useRef(0) as Box<number>;
const [n, setN] = useState("0");
const [still, setStill] = useState(false);
const vars: Vars = { "--duration": duration, "--easing": easing, "--color": color };
function reduced(): boolean {
return window.matchMedia("(prefers-reduced-motion: reduce)").matches;
}
function tokRGB(root: HTMLDivElement, name: string): RGB {
const s = getComputedStyle(root).getPropertyValue(name).trim();
const hx = s.length === 4
? s.charAt(1) + s.charAt(1) + s.charAt(2) + s.charAt(2) + s.charAt(3) + s.charAt(3)
: s.slice(1);
return [parseInt(hx.slice(0, 2), 16), parseInt(hx.slice(2, 4), 16), parseInt(hx.slice(4, 6), 16)];
}
function buildPerm(): void {
const rand = randRef.current;
const p: number[] = [];
for (let i = 0; i < 256; i++) p.push(i);
for (let i2 = 255; i2 > 0; i2--) {
const k2 = Math.floor(rand() * (i2 + 1));
const tmp = p[i2]; p[i2] = p[k2]; p[k2] = tmp;
}
const perm = new Uint8Array(512);
for (let i3 = 0; i3 < 512; i3++) perm[i3] = p[i3 & 255];
permRef.current = perm;
}
function fade(k: number): number { return k * k * (3 - 2 * k); }
function vnoise(x: number, y: number): number {
const perm = permRef.current;
const xi = Math.floor(x), yi = Math.floor(y);
const xf = x - xi, yf = y - yi;
const a2 = perm[(perm[xi & 255] + yi) & 255];
const b2 = perm[(perm[(xi + 1) & 255] + yi) & 255];
const c2 = perm[(perm[xi & 255] + yi + 1) & 255];
const d2 = perm[(perm[(xi + 1) & 255] + yi + 1) & 255];
const u = fade(xf), v = fade(yf);
return (a2 + (b2 - a2) * u + (c2 - a2) * v + (a2 - b2 - c2 + d2) * u * v) / 255;
}
function clampIdx(x: number, y: number): number {
const fw = fwRef.current, fh = fhRef.current;
const xx = Math.max(0, Math.min(fw - 1, Math.round(x)));
const yy = Math.max(0, Math.min(fh - 1, Math.round(y)));
return yy * fw + xx;
}
function buildMaze(): void {
const rand = randRef.current;
const fw = fwRef.current, fh = fhRef.current;
const cellW = fw / MAZE_COLS, cellH = fh / MAZE_ROWS;
const rightOpen = new Uint8Array(MAZE_COLS * MAZE_ROWS);
const downOpen = new Uint8Array(MAZE_COLS * MAZE_ROWS);
const vis = new Uint8Array(MAZE_COLS * MAZE_ROWS);
const midR = MAZE_ROWS >> 1;
const stack: [number, number][] = [[0, midR]];
vis[midR * MAZE_COLS] = 1;
while (stack.length) {
const cur = stack[stack.length - 1];
const c = cur[0], r = cur[1];
const nbrs: [number, number, string][] = [];
if (c > 0 && !vis[r * MAZE_COLS + (c - 1)]) nbrs.push([c - 1, r, "L"]);
if (c < MAZE_COLS - 1 && !vis[r * MAZE_COLS + (c + 1)]) nbrs.push([c + 1, r, "R"]);
if (r > 0 && !vis[(r - 1) * MAZE_COLS + c]) nbrs.push([c, r - 1, "U"]);
if (r < MAZE_ROWS - 1 && !vis[(r + 1) * MAZE_COLS + c]) nbrs.push([c, r + 1, "D"]);
if (!nbrs.length) { stack.pop(); continue; }
const pick = nbrs[Math.floor(rand() * nbrs.length)];
if (pick[2] === "R") rightOpen[r * MAZE_COLS + c] = 1;
if (pick[2] === "L") rightOpen[r * MAZE_COLS + (c - 1)] = 1;
if (pick[2] === "D") downOpen[r * MAZE_COLS + c] = 1;
if (pick[2] === "U") downOpen[(r - 1) * MAZE_COLS + c] = 1;
vis[pick[1] * MAZE_COLS + pick[0]] = 1;
stack.push([pick[0], pick[1]]);
}
const obstacle = new Uint8Array(fw * fh);
for (let i = 0; i < obstacle.length; i++) obstacle[i] = 1;
const wt = WALL_T;
for (let rr = 0; rr < MAZE_ROWS; rr++) {
for (let cc = 0; cc < MAZE_COLS; cc++) {
const x0 = Math.round(cc * cellW), y0 = Math.round(rr * cellH);
const x1 = Math.round((cc + 1) * cellW), y1 = Math.round((rr + 1) * cellH);
for (let y = y0 + wt; y < y1 - wt; y++) {
for (let x = x0 + wt; x < x1 - wt; x++) {
if (x >= 0 && x < fw && y >= 0 && y < fh) obstacle[y * fw + x] = 0;
}
}
if (rightOpen[rr * MAZE_COLS + cc]) {
for (let y2 = y0 + wt; y2 < y1 - wt; y2++) {
for (let x2 = x1 - wt; x2 < x1 + wt; x2++) {
if (x2 >= 0 && x2 < fw && y2 >= 0 && y2 < fh) obstacle[y2 * fw + x2] = 0;
}
}
}
if (downOpen[rr * MAZE_COLS + cc]) {
for (let y3 = y1 - wt; y3 < y1 + wt; y3++) {
for (let x3 = x0 + wt; x3 < x1 - wt; x3++) {
if (x3 >= 0 && x3 < fw && y3 >= 0 && y3 < fh) obstacle[y3 * fw + x3] = 0;
}
}
}
}
}
obstacleRef.current = obstacle;
foodARef.current = [Math.round(cellW * 0.5), Math.round(cellH * (midR + 0.5))];
foodBRef.current = [Math.round(cellW * (MAZE_COLS - 0.5)), Math.round(cellH * (midR + 0.5))];
}
function buildFood(): void {
const fw = fwRef.current, fh = fhRef.current;
const food = new Float32Array(fw * fh);
const pts = [foodARef.current, foodBRef.current];
for (let y = 0; y < fh; y++) {
for (let x = 0; x < fw; x++) {
let best = 0;
for (let p = 0; p < pts.length; p++) {
const dx = x - pts[p][0], dy = y - pts[p][1];
const d2 = dx * dx + dy * dy;
const v = Math.exp(-d2 / (fw * 1.1));
if (v > best) best = v;
}
food[y * fw + x] = best;
}
}
foodRef.current = food;
}
function sense(x: number, y: number): number {
const i = clampIdx(x, y);
if (obstacleRef.current[i]) return -1000;
return trailRef.current[i] + foodRef.current[i] * foodWRef.current * CAP;
}
function initAgents(): void {
const rand = randRef.current;
const obstacle = obstacleRef.current;
const fw = fwRef.current;
const A = agentsRef.current;
const open: number[] = [];
for (let i = 0; i < obstacle.length; i++) if (!obstacle[i]) open.push(i);
const ax = new Float32Array(A), ay = new Float32Array(A), ah = new Float32Array(A);
for (let k = 0; k < A; k++) {
const oi = open[Math.floor(rand() * open.length)];
ax[k] = oi % fw; ay[k] = Math.floor(oi / fw);
ah[k] = rand() * Math.PI * 2;
}
axRef.current = ax; ayRef.current = ay; ahRef.current = ah;
}
function stepAgents(): void {
const rand = randRef.current;
const A = agentsRef.current;
const fw = fwRef.current, fh = fhRef.current;
const ax = axRef.current, ay = ayRef.current, ah = ahRef.current;
const trail = trailRef.current;
const obstacle = obstacleRef.current;
for (let i = 0; i < A; i++) {
const x = ax[i], y = ay[i];
let h = ah[i];
const sf = sense(x + Math.cos(h) * SENSOR_DIST, y + Math.sin(h) * SENSOR_DIST);
const sl = sense(x + Math.cos(h + SENSOR_ANGLE) * SENSOR_DIST, y + Math.sin(h + SENSOR_ANGLE) * SENSOR_DIST);
const sr = sense(x + Math.cos(h - SENSOR_ANGLE) * SENSOR_DIST, y + Math.sin(h - SENSOR_ANGLE) * SENSOR_DIST);
if (sf >= sl && sf >= sr) {
// 직진
} else if (sl > sr) {
h += TURN;
} else if (sr > sl) {
h -= TURN;
} else {
h += (rand() < 0.5 ? 1 : -1) * TURN;
}
h += (rand() - 0.5) * 0.16;
const nx = x + Math.cos(h) * STEP, ny = y + Math.sin(h) * STEP;
const ni = clampIdx(nx, ny);
if (obstacle[ni]) {
h += Math.PI * 0.5 + (rand() - 0.5) * Math.PI;
} else {
ax[i] = Math.max(0, Math.min(fw - 1, nx));
ay[i] = Math.max(0, Math.min(fh - 1, ny));
trail[ni] = Math.min(CAP, trail[ni] + DEPOSIT);
}
ah[i] = h;
}
stepCountRef.current++;
}
function diffuseEvap(): void {
const fw = fwRef.current, fh = fhRef.current;
const trail = trailRef.current, trailB = trailBRef.current;
const obstacle = obstacleRef.current;
const dc = decayRef.current;
for (let y = 0; y < fh; y++) {
const ym = y === 0 ? 0 : y - 1, yp = y === fh - 1 ? fh - 1 : y + 1;
for (let x = 0; x < fw; x++) {
const i = y * fw + x;
if (obstacle[i]) { trailB[i] = 0; continue; }
const xm = x === 0 ? 0 : x - 1, xp = x === fw - 1 ? fw - 1 : x + 1;
const avg = (trail[y * fw + xm] + trail[y * fw + xp] + trail[ym * fw + x] + trail[yp * fw + x]) * 0.25;
trailB[i] = (trail[i] * (1 - DIFFUSE) + avg * DIFFUSE) * (1 - dc);
}
}
trailRef.current = trailB; trailBRef.current = trail;
}
function render(t: number): void {
const ctx = ctxRef.current;
const col = colRef.current;
const img = imgRef.current;
if (!ctx || !col || !img) return;
const fw = fwRef.current, fh = fhRef.current;
const trail = trailRef.current;
const obstacle = obstacleRef.current;
const foodA = foodARef.current, foodB = foodBRef.current;
const data = img.data;
const pa = 0.55 + 0.45 * Math.sin(t * 2.6);
const pb = 0.55 + 0.45 * Math.sin(t * 2.6 + 2.1);
for (let y = 0; y < fh; y++) {
for (let x = 0; x < fw; x++) {
const i = y * fw + x;
const j = i * 4;
const n1 = vnoise(x * 0.09, y * 0.09 + t * 0.9);
const n2 = vnoise(x * 0.03 + 40, y * 0.03 + t * 0.6);
const sh = (n1 - 0.5) * 30 + (n2 - 0.5) * 20;
if (obstacle[i]) {
data[j] = col.wall[0] + sh; data[j + 1] = col.wall[1] + sh; data[j + 2] = col.wall[2] + sh; data[j + 3] = 255;
continue;
}
let v = trail[i] / CAP; if (v > 1) v = 1;
const k = v * v * (3 - 2 * v);
let rr = col.floor[0] + (col.trail[0] - col.floor[0]) * k;
let gg = col.floor[1] + (col.trail[1] - col.floor[1]) * k;
let bb = col.floor[2] + (col.trail[2] - col.floor[2]) * k;
const dA = Math.hypot(x - foodA[0], y - foodA[1]);
const dB = Math.hypot(x - foodB[0], y - foodB[1]);
const glow = Math.max(Math.exp(-dA * dA / 26) * pa, Math.exp(-dB * dB / 26) * pb);
rr += (col.food[0] - rr) * glow; gg += (col.food[1] - gg) * glow; bb += (col.food[2] - bb) * glow;
rr += sh; gg += sh; bb += sh;
data[j] = rr; data[j + 1] = gg; data[j + 2] = bb; data[j + 3] = 255;
}
}
ctx.putImageData(img, 0, 0);
}
function fit(): void {
const field = fieldRef.current;
const cv = cvRef.current;
if (!field || !cv) return;
const r = field.getBoundingClientRect();
const W = Math.round(r.width), H = Math.round(r.height);
const fw = Math.max(96, Math.min(200, Math.round(W / 3)));
const fh = Math.max(52, Math.min(120, Math.round(H / 3)));
fwRef.current = fw; fhRef.current = fh;
cv.width = fw; cv.height = fh;
cv.style.width = "100%"; cv.style.height = "100%";
const ctx = cv.getContext("2d", { alpha: false });
if (!ctx) return;
ctxRef.current = ctx;
const img = ctx.createImageData(fw, fh);
imgRef.current = img;
trailRef.current = new Float32Array(fw * fh);
trailBRef.current = new Float32Array(fw * fh);
stepCountRef.current = 0;
buildMaze();
buildFood();
initAgents();
}
function stillFrame(): void {
for (let k = 0; k < 260; k++) { stepAgents(); diffuseEvap(); }
render(1.9);
}
let t0 = -1;
function frame(now: number): void {
if (t0 < 0) t0 = now;
const t = (now - t0) / 1000;
for (let s = 0; s < SUBSTEPS; s++) { stepAgents(); diffuseEvap(); }
render(t);
setN(String(stepCountRef.current));
rafRef.current = requestAnimationFrame(frame);
}
useEffect(() => {
const root = rootRef.current;
if (!root) return;
agentsRef.current = agents;
decayRef.current = decay;
foodWRef.current = foodWeight;
randRef.current = makePRNG(0x320a02);
colRef.current = {
floor: tokRGB(root, "--sm-floor"),
wall: tokRGB(root, "--sm-wall"),
trail: tokRGB(root, "--sm-trail"),
food: tokRGB(root, "--sm-food"),
};
buildPerm();
fit();
setN("0");
function onResize(): void {
fit();
if (reduced()) stillFrame();
}
window.addEventListener("resize", onResize);
if (reduced()) {
stillFrame();
setStill(true);
} else {
t0 = -1;
rafRef.current = requestAnimationFrame(frame);
}
return () => {
window.removeEventListener("resize", onResize);
cancelAnimationFrame(rafRef.current);
};
// eslint-disable-next-line react-hooks/exhaustive-deps
}, [agents, decay, foodWeight]);
const rootCls = still ? `${styles.root} ${styles.isStill}` : styles.root;
return (
<main className={styles.stage}>
<div className={rootCls} ref={rootRef} style={vars}>
<p className={styles.hint}>
<span>미로 벽을 장애물 필드로 깔고 입구·출구에 먹이를 두면, 점균 네트워크가 막다른 길의 트레일부터 말라 없어지고 가장 짧은 통로만 굵어지며 스스로 최단경로를 찾아냅니다</span>
</p>
<div
className={styles.field}
ref={fieldRef}
role="application"
aria-label={FIELD_LABEL}
tabIndex={0}
>
<canvas className={styles.cv} ref={cvRef}></canvas>
</div>
<div className={styles.bar}>
<span className={styles.meta}><b className={styles.val}>{n}</b> 탐색 스텝 · 미로 풀이</span>
<span className={styles.metaDim}>canvas · ImageData · requestAnimationFrame</span>
</div>
</div>
</main>
);
}02 미로 최단경로 — 이그노벨상 실험을 캔버스로 재현 — 측정 누적면적 43.166% · 움직인 프레임 23/23GODRICH 원작 · zip 에 SCSS·React 포함 · 슬라임몰드 길찾기 9종 — 점균 네트워크가 스스로 최단경로를 찾는 캔버스
이 데모가 속한 글
 슬라임몰드 길찾기 9종 — 점균 네트워크가 스스로 최단경로를 찾는 캔버스슬라임몰드 길찾기를 캔버스 픽셀 계산만으로 재현합니다. 라이브러리·WebGL 없이 화면 위를 기어다니는 점 하나하나가 앞·좌·우 냄새를 맡고 진한 쪽으로 도는 규칙만 반복하는 것으로, 미로의 최단경로를 스스로 찾아내 이 글의 데모 전부 보기